Conference paper · 2025
Isaac Sim-to-Real: Reinforcement Learning based Locomotion for Quadrupeds
2025 IEEE 21st International Conference on Automation Science and Engineering (CASE) · pp. 2194–2199
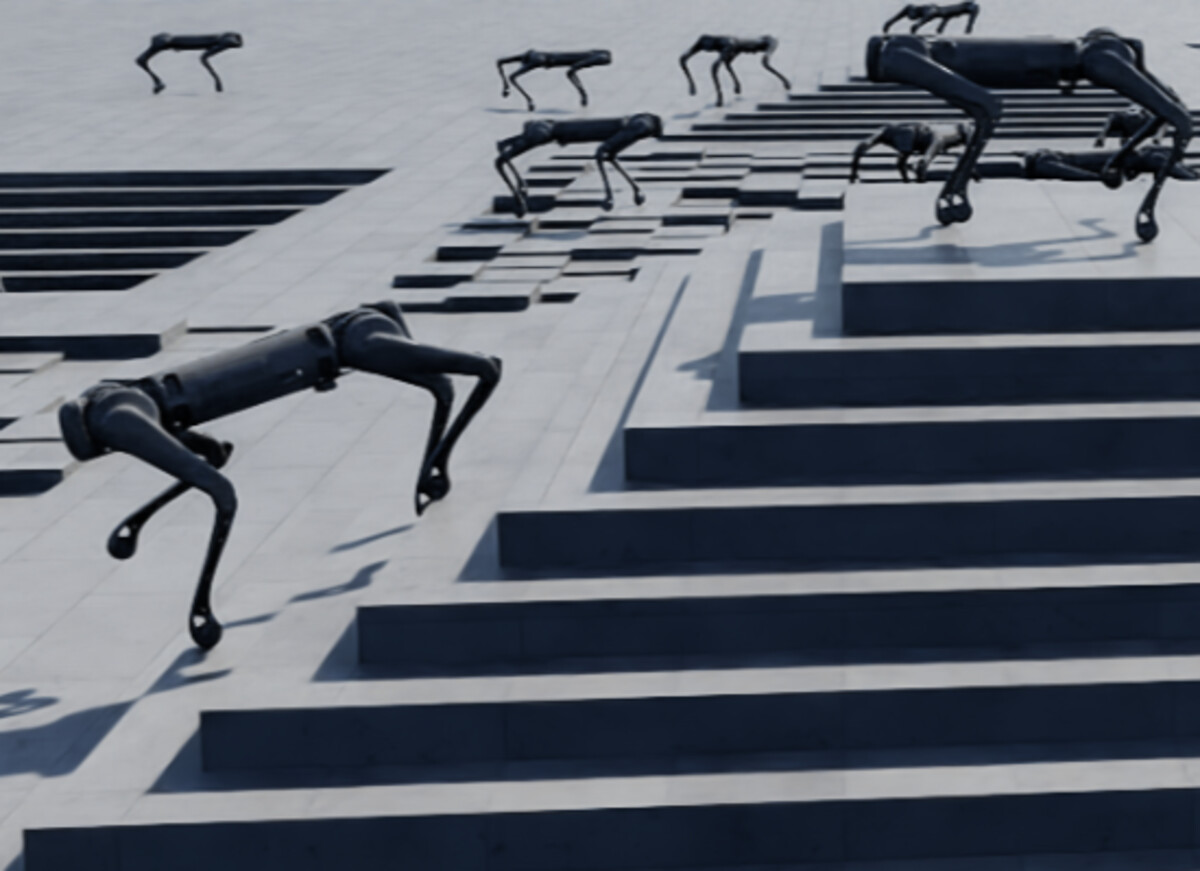
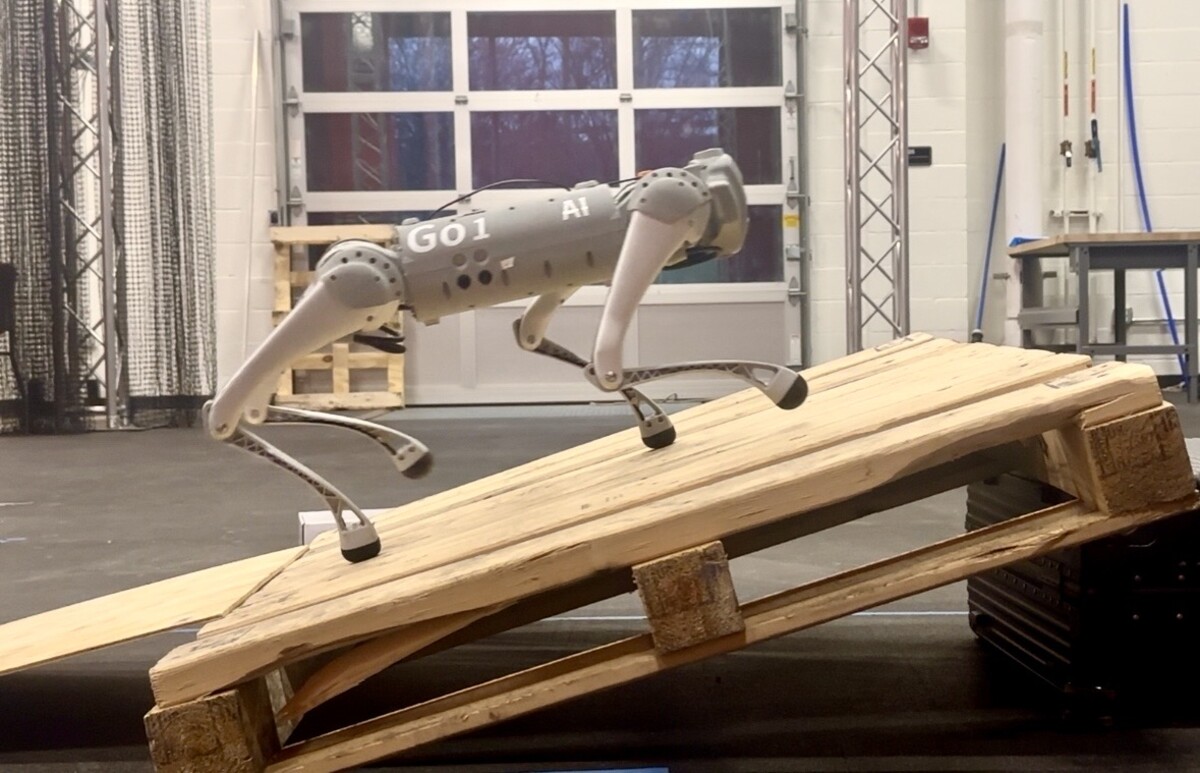
A reinforcement-learning locomotion pipeline trains in NVIDIA Isaac Sim and transfers to a physical Unitree Go1 for real-world evaluation.